BrainCo Revo 3-21 Basic Robot Hand
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 3-21 BASIC
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-3
BrainCo Revo 3-21 Basic Robot Hand
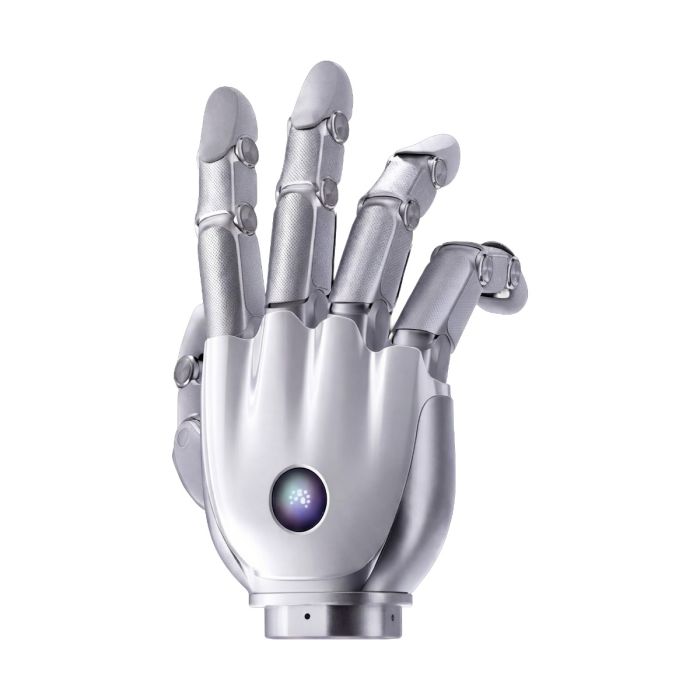
A concert pianist does not play with one finger pressing down and then lifting; every joint of the hand contributes its own small motion to the phrase. Most robot end-effectors still behave like the single-finger version. The BrainCo Revo 3-21 Basic Robot Hand is built on the opposite idea: a hand in which each finger segment answers to its own motor, so that a grasp is composed rather than merely triggered. It is a tool for teams who have reached the limit of what jaws can do.
The product is available through this page, by quotation.
Background
BrainCo and the Revo family
BrainCo was founded in 2015 and now offers three robotic products. Its dexterous hands have been released as a numbered family, and this store lists several of them: the Revo 1 Intelligent Dexterous Bionic Hand, the Revo 2 left and right hands, and the Revo 3 range described here. Readers who wish to see the whole generation together can browse the BrainCo Revo 3 category.
The Revo 3 is a biomimetic dexterous hand. Its stated purposes are industrial automation, scientific research and advanced robotics manipulation, which describes a fairly broad audience: production engineers who need to handle varied parts, and university laboratories that study grasping, in-hand manipulation and human-like motion.
Positioning and key technology
The central technical claim of the Revo 3 is its architecture. It has 21 fully active, independently driven degrees of freedom: five in the thumb and four in each of the index, middle, ring and pinky fingers. The thumb receives the largest share, as it does in a human hand, because opposing the thumb to the fingers is what makes pinching, wrapping and tool use possible.
The joints are direct-driven and backdrivable. In practical terms, this means that the mechanism can be moved from the outside and can follow an applied force, which suits compliant control and makes contact with objects gentler than with a rigid, geared transmission. The same design gives rapid response and high control density across all finger segments.
The hand is rated for more than 1,000,000 joint flex cycles, a figure that matters to anyone planning a repetitive workcell rather than a single demonstration. Development is supported by cross-platform C/C++ and Python SDKs for Linux and Windows, so that the hand can be driven from the languages that robotics teams already use.
Technical Specifications
The table below sets the manufacturer's table beside the figures given for the Revo 3 Basic, since the two do not always agree. A dash marks an empty cell.
| Specification | Manufacturer table | Revo 3 Basic |
|---|---|---|
| Degrees of freedom | 21 | 21 |
| Drive type | Direct-driven, backdrivable | Direct-driven, backdrivable |
| Hand dimensions | 216 × 108 × 50 mm | 215 × 105 × 50 mm |
| Supply voltage | 16–85 V | 12–80 V |
| Max current | 10 A (24 V) | — |
| Max active grip force | ≥100 N | >70 N |
| Max fingertip pinch force | ≥25 N | — |
| Total hand payload | 20 kg | — |
| Four-finger payload | 5 kg | — |
| Repeatability | 0.1° | — |
| Joint open/close time | 0.33 s | — |
| Max grasping diameter | 150 mm | — |
| Communication interfaces | EtherCAT / CAN FD / RS-485 | — |
| Communication frequency | 500 Hz | — |
| Onboard sensors | IMU (mainboard), temperature (mainboard) | — |
| Tactile sensors | — | Not included |
| Control modes | — | Position / MIT Force-Position / Admittance / Zero-Torque |
| Rated life | Over 1,000,000 joint flex cycles | Over 1,000,000 joint flex cycles |
| SDKs | C/C++ and Python (Linux, Windows) | C/C++ and Python (Linux, Windows) |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the weight, the box contents, the IP rating, the operating temperature range or the power consumption; they are confirmed at quotation.
What makes the Revo 3 Basic different from a conventional gripper?
A two-jaw or three-jaw gripper has one or two degrees of freedom, and the object has to be presented to it in a suitable orientation. The Revo 3 Basic has 21. It can form a pinch between the thumb and a fingertip, wrap its fingers around a cylinder, or open only the fingers that are in the way. That flexibility moves complexity from the workcell, where fixtures and feeders must be designed for every part, into the hand and its software.
The second difference is how the joints behave under load. Because they are direct-driven and backdrivable, the fingers respond quickly and can yield to contact. For the Basic, the listed control modes are Position, MIT Force-Position, Admittance and Zero-Torque. Position control suits repeatable, scripted motion; the force-position and admittance modes suit contact-rich tasks; and zero-torque lets a person move the fingers freely, which is useful when teaching or inspecting a pose.
The third difference is integration. The manufacturer's table lists EtherCAT, CAN FD and RS-485 interfaces with a communication frequency of 500 Hz, and the C/C++ and Python SDKs run on both Linux and Windows. A laboratory that already works in Python can therefore begin without writing low-level drivers from scratch.
What does the Basic version leave out?
The Basic is listed without tactile sensors. The hand moves precisely, but it does not report touch at the fingertip, so any feedback must come from elsewhere in the system, such as the arm, a camera or the joint behaviour itself. Teams whose work depends on sensing contact should compare it with the BrainCo Revo 3-21 Touch Robot Hand or the BrainCo Revo 3-21 V-Touch Robot Hand before deciding.
Note also that the figures for the Basic differ from those in the manufacturer's table: the Basic listing gives an active grasping force above 70 N, a supply range of 12–80 V and overall dimensions of 215 × 105 × 50 mm. These figures stay with the Basic and deserve attention when power supplies are being specified.
Who is the BrainCo Revo 3-21 Basic Robot Hand for?
Research laboratories are the clearest audience. A hand with 21 independent degrees of freedom, control modes beyond plain position control, and open SDKs gives students and researchers a platform for studying grasping, manipulation and imitation of human motion without building a hand themselves.
Integrators and automation engineers form the second group. Where parts vary in shape, or where a human-like hand is wanted because tools and workstations were designed for people, a dexterous hand can replace several specialised grippers. The Basic suits those who will supply their own sensing or whose task does not depend on touch feedback.
Developers of humanoid and advanced manipulation platforms are the third group. Those who need tactile feedback at the fingertip should look at the Touch version instead, and those who need a simpler step into BrainCo hands may compare the earlier Revo 2 models, such as the BrainCo Revo 2 Basic Right Dexterous Bionic Hand (XRR).
What is the BrainCo Revo 3-21 Basic Robot Hand used for?
- Dexterous manipulation research: studying how finger coordination produces stable grasps and in-hand motion.
- Industrial automation: handling varied parts in a single workcell without changing tools.
- Humanoid robot development: giving a humanoid platform a hand with human-like finger layout.
- Teleoperation and demonstration: using the zero-torque mode and the SDKs to record and replay hand poses.
- Compliant contact experiments: testing admittance and force-position control on backdrivable joints.
- Teaching and training: giving students a hands-on platform for robotics, control and software courses.
Pricing and Availability
We do not publish prices for this hand. The way to proceed is to request a quotation, which sets out the configuration for the version you need. Delivery, customs and support are arranged with the quotation. The BrainCo Revo 3-21 Basic Robot Hand is available on this page.
Frequently Asked Questions
How many degrees of freedom does the Revo 3 Basic have?
It has 21 fully active, independently driven degrees of freedom: five in the thumb and four in each of the index, middle, ring and pinky fingers.
Are the joints backdrivable?
Yes. The joints are direct-driven and backdrivable, which gives rapid response and allows the fingers to follow an applied force.
Does the Basic version include tactile sensors?
No. Tactile sensors are not included in the Basic. For touch feedback, compare the Touch and V-Touch versions.
Which programming languages and operating systems are supported?
Cross-platform C/C++ and Python SDKs are available for Linux and Windows.
Which control modes does the Basic offer?
The listed modes are Position, MIT Force-Position, Admittance and Zero-Torque.
What is the IP rating, weight or operating temperature range?
None of these appears in the specification table; the note beneath the table covers them, together with the power consumption and the box contents.
Where can I buy the BrainCo Revo 3-21 Basic Robot Hand and what does it cost?
It is available through this page by quotation. The quotation sets out the commercial terms, together with delivery and support arrangements.
Summary
The Revo 3-21 Basic takes the idea of a composed grasp seriously: 21 independently driven degrees of freedom, direct-driven backdrivable joints, a rated life above 1,000,000 flex cycles and SDKs in C/C++ and Python. It leaves out tactile sensing, and its figures should be read column by column. For laboratories, integrators and humanoid developers who have outgrown simple jaws, this page is the starting point.