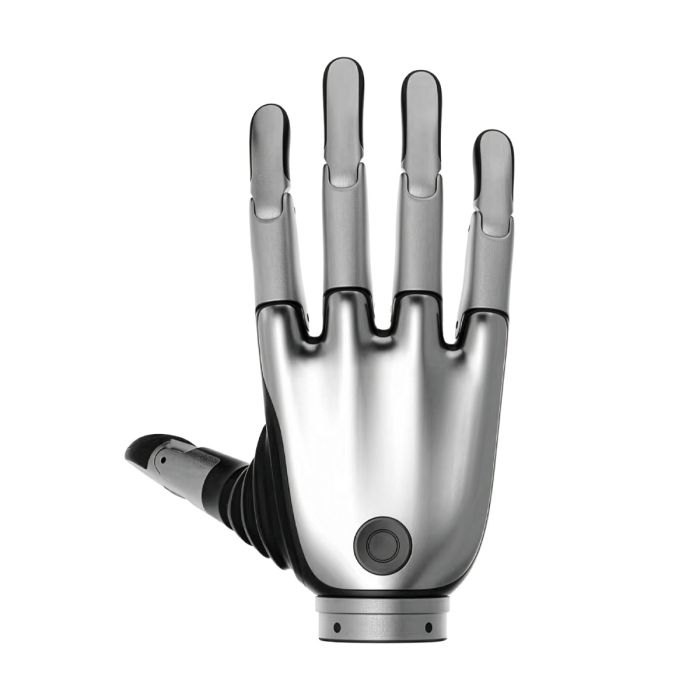
BrainCo Revo 2 Pro Dexterous Left Hand (XEL)
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 2 PRO
- PART #:
- XEL
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Pro-Left
BrainCo Revo 2 Pro Dexterous Left Hand (XEL)
Between a robot's wrist and the object it must lift lies the most unforgiving centimetre of engineering: the hand. The BrainCo Revo 2 Pro Dexterous Left Hand (XEL) addresses that gap with a bionic mechanism designed for robot integration and research, and it does so for the left side of the machine, where two-handed work so often begins.
The product is available through this page, by quotation.
Background
BrainCo and the Revo 2 lineage
BrainCo develops bionic and neural-interface technology, and the Revo 2 series carries that heritage into dexterous robot hands. The series is offered in three versions, each as a left and a right unit. The Basic version carries the codes XRL and XRR, the Pro version XEL and XER, and the Touch version XTL and XTR. The unit described on this page is the Pro left hand, coded XEL.
The Revo 2 hand has 6 active joints and a total of 11 degrees of freedom. In practical terms, a modest number of actuated joints drives a larger number of articulated ones, which allows a human-scaled hand to shape itself around varied objects without the bulk of one motor per joint.
Where the Pro version sits
The Pro tier is the middle step of the range. It is intended for teams that need more than a demonstration unit but do not require the tactile emphasis of the Touch version. Buyers who prefer to compare across the range may consult the BrainCo Revo 2 category, where every version is gathered.
The Revo 2 documentation lists RS485, CAN FD and EtherCAT communication interfaces, together with SDK support for Linux, Windows and ROS workflows. Those choices matter to an integrator, because the way a hand talks to its controller often decides how quickly it can be commissioned.
Technical Specifications
| Specification | Value |
|---|---|
| Version code | XEL (Pro, left hand); the right-hand Pro unit is XER |
| Active joints | 6 |
| Total degrees of freedom | 11 |
| Pinch force | ≥15N |
| Control precision | 0.1° |
| Smart protection | Current protection, stall protection, high-temperature protection, anti-collision protection |
| SDK support | Linux, Windows and ROS workflows |
| Standard colours | Space Gray, Silver (bulk colour customisation supported) |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the Pro-specific weight, the IP rating, the contents of the box, the cable length or the certifications; they are confirmed at quotation.
What makes the Pro left hand different from a single-purpose gripper?
A parallel gripper closes on an object along one axis. A hand with 11 degrees of freedom can do something quite different: it can wrap, pinch, hold and release, and it can adopt a posture that suits the object rather than forcing the object to suit the tool. That is the central argument for any dexterous hand, and the Revo 2 Pro XEL is built to make it in a package of human proportions.
Closed-loop servo control and custom gesture definitions support that argument. A team can define the postures a task requires and call them repeatedly, instead of rebuilding every grasp from individual joint commands. The control precision of 0.1° gives those postures a fine resolution, and the pinch force of ≥15N shows that the hand is meant to hold objects with intent rather than merely touch them.
Protection is the other half of the answer. The hand includes current protection, stall protection, high-temperature protection and anti-collision protection. In a research laboratory, where a new controller may misbehave on its first afternoon, those safeguards reduce the risk that an experimental error becomes damaged hardware.
How does the Pro version relate to the Basic and Touch versions?
The three versions share the Revo 2 architecture of 6 active joints and 11 degrees of freedom, and they differ in tier. The Basic version, available as the XRL left unit and the XRR right unit, is the entry configuration. The Touch version, in left (XTL) and right (XTR) forms, is the tier named for tactile sensing. The Pro version, coded XEL and XER, is the tier between them.
A buyer who needs a particular supply, interface or sensing arrangement should state it in the quotation request, so that the answer is given for the XEL unit and not for another version.
Who is the BrainCo Revo 2 Pro Dexterous Left Hand (XEL) for?
Research laboratories are the clearest audience. A hand that supports Linux, Windows and ROS workflows can enter an existing software stack without a rewrite, and the custom gesture definitions allow students and researchers to build task libraries quickly.
Humanoid developers form the second segment. A humanoid needs two hands, and the left deserves the same care as the right. Those building a matched pair can pair this unit with the BrainCo Revo 2 Pro Dexterous Right Hand (XER), which belongs to the same Pro tier.
System integrators are the third. They value communication options and protective behaviours because a cell must run for long periods and recover predictably from faults. Buyers whose work depends chiefly on tactile feedback should look at the Touch version, while those with a simpler task and a tighter scope may find the Basic version sufficient.
What is the BrainCo Revo 2 Pro Dexterous Left Hand (XEL) used for?
- Humanoid robot integration. The hand serves as the left end effector of a humanoid platform that must handle everyday objects.
- Manipulation research. Laboratories use it to study grasp planning, in-hand motion and learning-based control.
- Two-handed assembly cells. Paired with a right-hand unit, it allows one hand to steady a part while the other works on it.
- Gesture-driven tasks. Custom gesture definitions let teams store and replay the postures a task repeatedly demands.
- Teaching and demonstration. A human-scaled hand with ROS support gives students a realistic platform for robotics coursework.
- Prototype development. Engineers use it to test grasping concepts before committing to a final end-effector design.
Pricing and Availability
No prices are shown on this page. Quotation is the route to a commercial offer: send the quantity, the preferred colour and the integration requirements, and a quotation will be prepared. Delivery, customs and support are arranged with the quotation. The BrainCo Revo 2 Pro Dexterous Left Hand (XEL) is available on this page.
Frequently Asked Questions
How many degrees of freedom does the hand have?
The Revo 2 hand has 6 active joints and a total of 11 degrees of freedom. The Pro left unit is coded XEL.
What protections are built in?
The hand includes current protection, stall protection, high-temperature protection and anti-collision protection. Closed-loop servo control and custom gesture definitions are also provided.
Which software environments are supported?
SDK support is provided for Linux, Windows and ROS workflows. This allows the hand to be brought into most research and integration environments.
What colours are available?
The standard colours are Space Gray and Silver. Bulk colour customisation is supported.
What is the pinch force and control precision?
The pinch force is ≥15N and the control precision is 0.1°.
Is there a right-hand version?
Yes. The right-hand Pro unit is coded XER and is offered as the BrainCo Revo 2 Pro Dexterous Right Hand (XER).
Where can I buy the BrainCo Revo 2 Pro Dexterous Left Hand (XEL) and what does it cost?
It can be bought through this page by requesting a quotation. The cost is provided in the quotation, together with delivery, customs and support arrangements.
Summary
The last centimetre of a robot arm is where its engineering is judged, and the BrainCo Revo 2 Pro Dexterous Left Hand (XEL) is designed for that moment. It offers 6 active joints, 11 degrees of freedom, a pinch force of ≥15N, 0.1° control precision, four protective functions and SDK support for Linux, Windows and ROS. For laboratories, humanoid developers and integrators who need a capable left hand, this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
Feature
1. High quality and stability – five years of product iteration and professional production lines.
2. Lightweight (383 grams), with 5 kg active grip force, 20 kg single-hand load capacity, and a grip-to-weight ratio of 53.
3. Ergonomic Bionic Design – supports curved surface grasping with anti- collision finger design.
4. Multi-dimensional tactile perception – pressure, friction, direction, proximity, and surface texture.
5. High Sensitivity Tactile Perception – max resolution of 0.01N.
6. Wide voltage support – 64V.
7. Universal Interfaces – RS485 & CAN-FD, and EtherCAT.
8. Standard Protocols and SDKs – Modbus & Protobuf protocols, SDKs for Python / C / ROS.