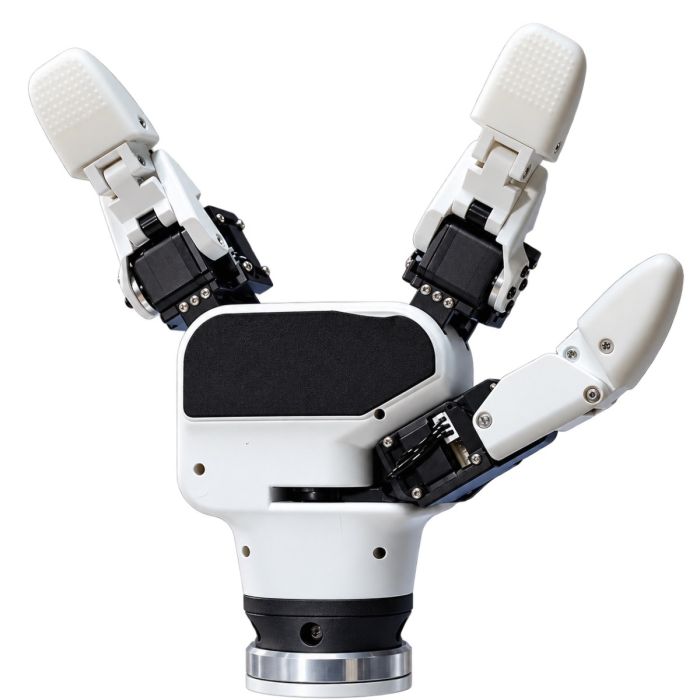
Elephant Robotics myGripper H100 Right Hand (4010700100)
In stock
- BRAND:
- ELEPHANT ROBOTICS
- MODEL:
- myGripper H100
- PART #:
- 4010700100
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Elephant Robotics Technology-4010700100
Elephant Robotics myGripper H100 Right Hand (4010700100)
A useful grasping experiment needs more than a successful pick: it needs movements that can be commanded, observed and studied. The Elephant Robotics myGripper H100 Right Hand (4010700100) brings those priorities together in a dexterous robotic hand for research and education. Its digital servo control and real-time status monitoring give developers a basis for investigating manipulation rather than treating the hand as a simple open-and-close accessory. For a laboratory or teaching team, the central question is how the hand fits the experiment, the software environment and the surrounding robotic system.
The product is available through this page, by quotation.
Background
Elephant Robotics and the H100 development brief
The myGripper H100 was developed by Shenzhen Elephant Robot Technology Co., Ltd. for robotics research, teaching and related applications. That brief places the emphasis on programmable movement and access to operating data. In educational robotics, a hand can serve both as a mechanism to study and as an end effector within a broader control exercise. In research, the same distinction matters: achieving a grasp and understanding the behaviour behind it are different objectives.
This page covers the Right Hand version. The named H100 range also includes Left Hand and Left+Right Hand versions. Selecting the correct configuration is part of defining the project, rather than a reason to assume that every version is interchangeable. The specifications below describe the product presented here; they are not a comparison of independently documented specifications for the other configurations.
Articulated movement and software access
The H100 uses 6 high performance digital servo motors and 6 movable joints. Its 3 fingers correspond to the human thumb, index finger and ring finger. Multi-parameter control covers output torque, motion speed and absolute position, giving a research programme distinct control variables to examine. This is a different starting point from an experiment concerned only with whether a gripper is open or closed.
A Python driver library is installable via PyPI. Compatibility with ROS1 and ROS2, together with RVIZ simulation support, provides routes into established robotics workflows. These tools are relevant when a project needs to connect movement commands, visualisation and data collection within a common development process.
Technical Specifications
| Specification | Value |
|---|---|
| Servo motors | 6 high performance digital servo motors |
| Communication frequency | 100Hz |
| Payload | 500g |
| Self-weight | 780g |
| Stroke (Diameter) | 0 – 130mm |
| Motion speed | 60 degrees per second per joint |
| Number of fingers | 3 fingers |
| Movable joints | 6 |
| Lifespan | 1,000,000 cycles or more |
| Power parameters | 24V, 2A |
| Main control processor frequency | 240MHz dual-core |
| Main control processing performance | 600 DMIPS |
| Main control SRAM | 520KB SRAM |
Specifications are as published by the manufacturer and are confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, IP rating, operating temperature range, gripping force or noise level; these details are confirmed at quotation.
What does the H100 offer for grasping research?
The H100 combines control of output torque, motion speed and absolute position with 100Hz communication for real-time status monitoring during grasping operations. That combination is relevant to experiments where the movement command and the observed state both form part of the record. A researcher can structure an investigation around control parameters, rather than documenting only the final position of an object.
The distinction between payload and grasp behaviour remains important when planning work. The 500g payload is a specification for the hand, not a statement that every object within that weight is suitable for every grasp. Object geometry, contact arrangement and the planned movement belong in the experimental assessment. A sound test programme defines those conditions before drawing conclusions about manipulation performance.
The articulated finger arrangement also gives teaching teams a concrete way to discuss the relationship between joint motion and contact with an object. Students can consider how a commanded movement changes the hand configuration, then relate that observation to the purpose of the grasp. This supports lessons centred on reasoning about manipulation rather than merely reproducing a demonstration.
How does the H100 fit a robotics development workflow?
The communication interface is RS485 and the protocol type is MODBUS. The electrical interface is an M8 Pin aviation connector, while the fixing method is screw fixing. These details define practical integration topics: the control connection, electrical connection and mechanical attachment each need attention. They should be reviewed together with the host system rather than treated as separate purchasing decisions.
The main control chip is ESP32, and its listed control features include Wi-Fi and dual-mode Bluetooth. These chip features do not replace the stated RS485 communication interface in an integration plan. Keeping the distinction clear helps a team specify the intended control path without assuming an undocumented wireless operating workflow.
Python access suits scripted development, while ROS1, ROS2 and RVIZ support are relevant to projects already organised around robotics software. Before commissioning, the project team should identify its software environment, intended commands and required data records. Naming a host robot alone does not establish the complete mechanical, electrical and software arrangement.
Who is myGripper H100 Right Hand for?
This version is intended for research groups, robotics educators and developers whose project calls for a right-hand configuration. It is relevant to teams studying articulated grasping, building teaching exercises around joint control, or developing software that links movement commands with operating data. Buyers working with Cobots should assess the end effector as part of the complete robotic installation, including mounting and the host system's operating requirements.
Where the project instead specifies a left-hand configuration, consider the myGripper H100 Left Hand. For a project requiring both named configurations, review the myGripper H100 Left+Right Hand option. The choice should follow the experimental layout and scope, not an assumption that the Right Hand version supplies a complete paired-hand arrangement.
What is myGripper H100 Right Hand used for?
- Grasping research: Investigate articulated object contact within a defined experimental procedure.
- Robotics teaching: Relate finger configuration and joint movement to the purpose of a grasp.
- Control development: Build exercises around output torque, motion speed and absolute-position commands.
- Data collection: Record real-time operating status during grasping experiments.
- Software integration: Develop Python or ROS workflows for a robotic manipulation project.
- Laboratory demonstrations: Present programmable hand movements as part of supervised robotics instruction.
Pricing and Availability
Request a quotation for the Right Hand version, identifying the project scope, host system and intended software environment. Include the planned mounting arrangement and any required integration assistance so that the proposed supply can be reviewed against the application. Delivery, customs and support are arranged with the quotation. The quotation request for this product is available on this page.
Frequently Asked Questions
Is this the Right Hand version?
Yes. This page is for myGripper H100 Right Hand, product code 4010700100. Left Hand and Left+Right Hand are separately named configurations.
How many fingers and movable joints does it have?
It has 3 fingers and 6 movable joints. The fingers correspond to the human thumb, index finger and ring finger.
Which movement parameters can be controlled?
The digital servo motors support control of output torque, motion speed and absolute position. These parameters provide distinct inputs for movement development and experimentation.
Does it support Python and ROS?
A Python driver library is installable via PyPI. The H100 is compatible with ROS1 and ROS2 and includes RVIZ simulation support.
What connection and mounting methods does it use?
It uses RS485 communication with MODBUS, an M8 Pin aviation connector and screw fixing. Review these interfaces alongside the intended host equipment when preparing the integration.
Can grasping status be monitored in real time?
Yes. The H100 supports 100Hz communication for real-time status monitoring during grasping operations and research data collection.
Where can I buy myGripper H100 Right Hand and what does it cost?
The product is available by quotation through this page. Submit the required configuration and application details to request a project-specific quotation.
Summary
The value of a grasping experiment lies not only in holding an object, but in understanding the movement that achieved it. The H100 Right Hand brings articulated motion, multi-parameter servo control and real-time monitoring into a research and teaching format, with Python and ROS support for development. A clear integration brief connects those capabilities to the intended experiment; for reviewing that brief and requesting a quotation, this page is the starting point.