Elephant Robotics myGripper H100 Left + Right Hand (4010700098)
In stock
- BRAND:
- ELEPHANT ROBOTICS
- MODEL:
- myGripper H100
- PART #:
- 4010700098
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Elephant Robotics Technology-4010700098
Elephant Robotics myGripper H100 Left + Right Hand (4010700098)
A successful grasp is more than a closed hand: researchers also need to understand the movement and monitor what happens during contact. Elephant Robotics myGripper H100 Left + Right Hand (4010700098) brings dexterous manipulation and grasping-status monitoring into the same research workflow. Developed for robotics research and education, the H100 combines articulated fingers with control of output torque, motion speed and absolute position. The emphasis is on making hand movement both controllable and observable, rather than treating gripping as a simple open-or-close command.
The product is available through this page, by quotation.
Background
Elephant Robotics and the H100's research focus
The myGripper H100 was developed by Shenzhen Elephant Robot Technology Co., Ltd. for robot scientific research, teaching and related applications. Its positioning places it in environments where the behaviour of a grasp matters as much as the outcome. In a teaching laboratory, that can mean examining the relationship between a movement command and the resulting hand position. In a research project, it can mean collecting grasping-status data while developing a manipulation routine.
The named compatible platforms are myCobot Pro 630 and the Mercury series. This gives buyers a defined starting point for platform selection, rather than a claim of universal robot-arm compatibility. A complete project still needs to address the hand, its mounting, electrical connection and software integration as parts of the same system.
Articulated movement with accessible feedback
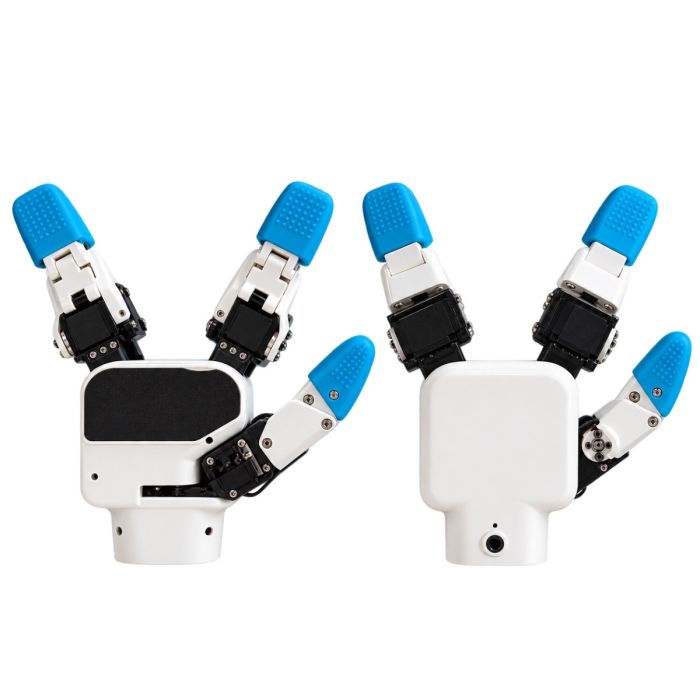
The H100 uses 3 fingers corresponding to the human thumb, index finger and ring finger, with 6 movable joints driven by 6 high performance digital servo motors. This is a particular hand arrangement, not a full reproduction of human anatomy. Its value for research lies in providing articulated movement with several controllable parameters.
The servo motors support current, position and speed control, while the hand provides control of output torque, motion speed and absolute position. Communication at 100Hz supports real-time status monitoring during grasping operations. Together, these features give a project a basis for studying movement and recording grasp behaviour through an instrumented workflow.
Technical Specifications
| Specification | Value |
|---|---|
| Servo motors | 6 |
| Number of fingers | 3 |
| Movable joints | 6 |
| Payload | 500g |
| Self-weight | 780g |
| Stroke (Diameter) | 0 – 130mm |
| Motion speed | 60 degrees per second per joint |
| Communication frequency | 100Hz |
| Lifespan | 1,000,000 cycles or more |
| Power parameters | 24V, 2A |
Specifications are as published by the manufacturer and are confirmed against the datasheet at quotation.
The manufacturer has not published dimensions, the IP rating, the operating temperature range, certifications, fingertip force in newtons or left and right hand weight differences; these details are confirmed at quotation.
The table presents the H100 hand specifications, not combined payload or weight totals for the Left + Right Hand selection. Communication uses RS485 and the MODBUS protocol, with an M8 Pin aviation connector for the electrical interface. The main control chip is ESP32, and the fixing method is screw fixing. These interface details belong in the integration brief alongside the numerical requirements.
How does the myGripper H100 support grasping research?
The central distinction is the combination of articulated movement and status monitoring. A grasping experiment can involve changing a command, observing movement and comparing the resulting data. The H100's output torque, motion speed and absolute-position control provide separate parameters around which such experiments can be organised. Its 100Hz communication supports real-time monitoring during the grasp rather than leaving observation solely to an external view.
Software support includes ROS1 and ROS2, together with the RVIZ simulation environment for displaying robot-arm state and collecting real-time data. A standardised robot driver library is downloadable through PyPI. For teams already working within a robotics software environment, these are concrete integration resources around which to plan development and teaching exercises.
Useful evaluation should distinguish between an available feature and an experimental result. Communication frequency, for example, describes the hand's communication capability; it does not by itself establish the performance of a complete robot application. Researchers should define the object, motion sequence, data requirements and success criteria before choosing how to use the available controls.
The same discipline applies to object selection. Payload and stroke are useful starting points, but neither alone describes the suitability of a particular grasp. Contact geometry, the intended movement and the consequences of dropping an object belong in the experimental plan. This keeps the investigation focused on measurable behaviour rather than assuming every object within an opening will be handled identically.
Who is myGripper H100 Left + Right Hand for?
This configuration addresses university laboratories, robotics researchers and teaching teams whose project calls for left and right hand arrangements. It is relevant where the curriculum or experiment concerns articulated grasping, motion control or the collection of manipulation data. Selecting handedness should follow the intended layout and research task, rather than simply choosing the broadest product option.
For a project requiring only a left-hand arrangement, consider the Elephant Robotics myGripper H100 Left Hand (4010700101). For a right-hand arrangement, consider the Elephant Robotics myGripper H100 Right Hand (4010700100). The selection here is Left + Right Hand; it should not be treated as a different performance grade merely because it names both orientations.
Buyers assessing a complete manipulation setup can also explore the Cobots category while keeping the H100's stated compatible models in view. Category membership is not a substitute for checking a specific arm and hand combination. For procurement teams, the most useful brief identifies the host platform, required handedness, teaching or research objective, and the interfaces the project will use.
What is myGripper H100 Left + Right Hand used for?
- Robotics teaching: Demonstrate how articulated finger movement relates to commanded position, speed and torque.
- Grasping research: Develop experiments that examine hand movement and grasping-status feedback together.
- Data collection: Record real-time grasping information within a structured research workflow.
- ROS integration studies: Build exercises around the supported ROS1 and ROS2 software environments.
- Visualisation exercises: Use RVIZ support when displaying robot-arm state and collecting real-time data.
- Handedness-focused project planning: Explore left and right hand arrangements within a defined manipulation study.
Pricing and Availability
Request a quotation for the Left + Right Hand configuration, identifying the intended robot platform and application. The quotation should define the supplied items and the integration requirements so that the project team can assess the complete scope, rather than relying on the product title as a packing list. Delivery, customs and support are arranged with the quotation. Requests for this configuration are available on this page.
Frequently Asked Questions
Which robot platforms are compatible?
The compatible models are myCobot Pro 630 and the Mercury series. Identify the exact host platform when requesting a quotation so that mounting and connection requirements form part of the project discussion.
Which movement parameters can I control?
The H100 provides control of output torque, motion speed and absolute position. Its servo motors support current, position and speed control.
Does the H100 support real-time grasping data collection?
Yes. It supports 100Hz communication for real-time status monitoring during grasping operations, supporting research data collection.
What software support is provided?
The H100 is compatible with ROS1 and ROS2 and supports the RVIZ simulation environment. A standardised robot driver library is downloadable through PyPI.
How does the hand connect to the control system?
The communication interface is RS485 and the protocol is MODBUS. The electrical interface is an M8 Pin aviation connector, and the specified power parameters are 24V, 2A.
How should I interpret the payload and weight figures?
The H100 specifications give a payload of 500g and a self-weight of 780g. These are hand specifications, not combined totals for the Left + Right Hand selection; do not double them to create an application rating.
Where can I buy myGripper H100 Left + Right Hand and what does it cost?
You can request the product through this page by quotation. State the required configuration and host robot so that the quotation addresses the intended application and supply scope.
Summary
The H100 makes the grasp itself a subject of study: articulated movement, controllable parameters and real-time status monitoring sit at the centre of its research and teaching role. The Left + Right Hand selection suits projects that need both handed arrangements, while the individual versions provide more focused alternatives. Define the experimental task, host platform and required supply scope before proceeding; for a quotation that brings those requirements together, this page is the starting point.