RoboParty ROMOMO 10062
In stock
- BRAND:
- RoboParty
- MODEL:
- ROMOMO 10062
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- RoboParty-ROMOMO-10062
RoboParty ROMOMO 10062
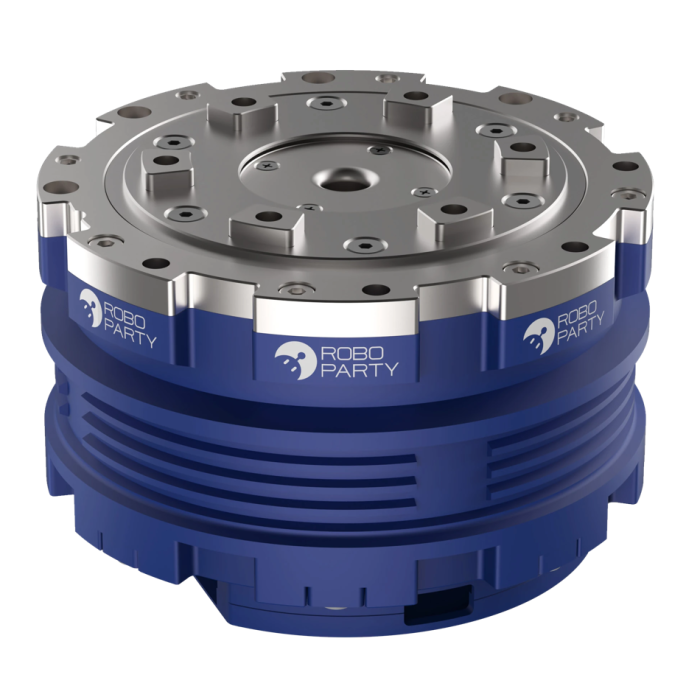
RoboParty ROMOMO 10062 is a robot joint module in the ROMOMO actuator family. Its own column in the manufacturer’s comparison table specifies 44 ±5% N·m rated torque, 160 N·m peak torque and a rated speed of 80 rpm. These model-specific values are important because the family includes several different torque, speed and mass combinations; specifications from another ROMOMO size should not be substituted.
Torque, Speed and Reduction
The ROMOMO 10062 reduction ratio is 22:1. The table distinguishes its rated speed of 80 rpm from a peak speed of 130 rpm. It also separates rated torque from peak torque. RoboParty explicitly states that peak parameters describe short-duration conditions rather than continuous output capability. A design requiring sustained torque must therefore be evaluated using the rated information and the relevant operating conditions, not the headline peak value.
The source lists a measured prototype mass of 1197 g. This is described as an actual measurement from laboratory test reporting, not as shipping weight or a published production-mass tolerance. The value is useful for an initial actuator mass budget, but a quotation or current drawing should establish what is included in the delivered assembly.
Additional motion entries include a no-load speed of 141 ±10% rpm, rated power of 370 ±5% W and backlash of 11.4 arcmin. No-load speed, rated speed and peak speed refer to different entries in the source and should remain distinct when comparing candidate modules. The tolerance annotations are retained because removing them would make the figures appear more exact than the manufacturer states.
Electrical Supply
The rated supply voltage is 48 V. This is a module specification rather than a complete robot power-system design. Selection of a power supply, protective devices and wiring requires the applicable module documentation and a defined duty cycle. The product page does not provide a complete thermal envelope or a guaranteed continuous operating condition for every installation.
Rated current is 11 ±5% A, with peak current of 55 ±10% A. Line resistance at 20 °C is 0.179 ±5% Ω, and line inductance is 0.244 ±10% mH. The back-EMF constant is 10.8 V/krpm, while the pole-pair count is 14. These electrical parameters belong to this model column; they should not be reused for another module simply because its supply voltage is also 48 V.
Control and Position Feedback
The comparison table lists CAN FD / EtherCAT communication and dual encoders. Encoder resolution is specified as 17 bit (inner ring)/ 19 bit (outer ring). For this model, the source uses inner-ring and outer-ring labels; these should be checked against the drawing before making a more specific interface interpretation.
Communication support and encoder resolution do not by themselves establish a complete controller configuration, update rate or closed-loop positioning accuracy. Integration should use the applicable protocol documentation and firmware information rather than inferring those properties from the bus names.
Mechanical and Material Limits
The published outer diameter is 100 mm, and the drawing-based axial dimension is 61.7 ±0.5 mm. Hollow diameter is 7.5 mm. Motor rotational inertia is listed as 60.6 kg·mm². These figures help define the component envelope and model inputs, but do not provide a complete mounting pattern or robot-joint load rating.
The manufacturer lists insulation class F (155 °C). This is an insulation-class entry, not an ambient operating-temperature specification or independent product certification. It must not be read as permission to operate the whole module continuously at 155 °C. The product page does not establish an ingress-protection rating or a certified safety function.
Interpreting the Drawing Constant
The torque-constant entry is labelled 0.163 N·m/A in the source drawing information. It is retained as a drawing-labelled value, not silently recalculated or normalised. The table does not explain whether all model constants use the same reference point or measurement convention. Developers should confirm that basis before applying the number in a motor model, current-to-torque estimate or comparison with another ROMOMO module.
Development and Selection
The family page describes clamp fixation, hollow cable routing and access to hardware drawings and driver source code. These are useful family-level design cues, but the exact model’s mounting and cable arrangement should be verified in its current documentation. The page specifically notes that hollow dimensions vary by model; the relevant dimension must come from the correct specification column.
Potential uses include robot-joint development and actuator evaluation where the required torque, speed, mass and electrical interface can be checked together. This is a component-selection context, not a claim that the module is a complete robot joint ready for every installation. A procurement enquiry should identify the exact model, control interface, supplied wiring, documentation revision and intended operating duty. No selling price or delivery commitment is established here.
Frequently Asked Questions
What is RoboParty ROMOMO 10062?
It is a ROMOMO robot joint module with a manufacturer-listed rated torque of 44 ±5% N·m and rated speed of 80 rpm. Sparse or missing entries should be checked against current model-specific documentation.
Can peak torque be used continuously?
No. The manufacturer identifies peak parameters as short-duration figures. The 160 N·m peak-torque entry must remain separate from the rated-torque specification.
What mass does the manufacturer publish?
The table lists 1197 g as measured prototype mass. That value is not a shipping weight and does not establish a production tolerance.
What are the benefits of model-specific selection?
Using the correct torque, speed, reduction and mass entries avoids transferring stronger or more complete specifications from another family member. Missing fields should be confirmed rather than guessed.
Where can I buy ROMOMO 10062?
Use RoboParty’s ROMOMO product page to request a current quotation and the exact model documentation. Confirm supplied interfaces, mechanical details and operating conditions before ordering.
Summary
ROMOMO 10062 should be evaluated as a distinct actuator, using its own rated and peak figures and preserving the manufacturer’s qualifications. Electrical and dimensional data provide a starting point for engineering review, while duty-cycle limits and configuration details require confirmation.